← All products
Dexterous hands
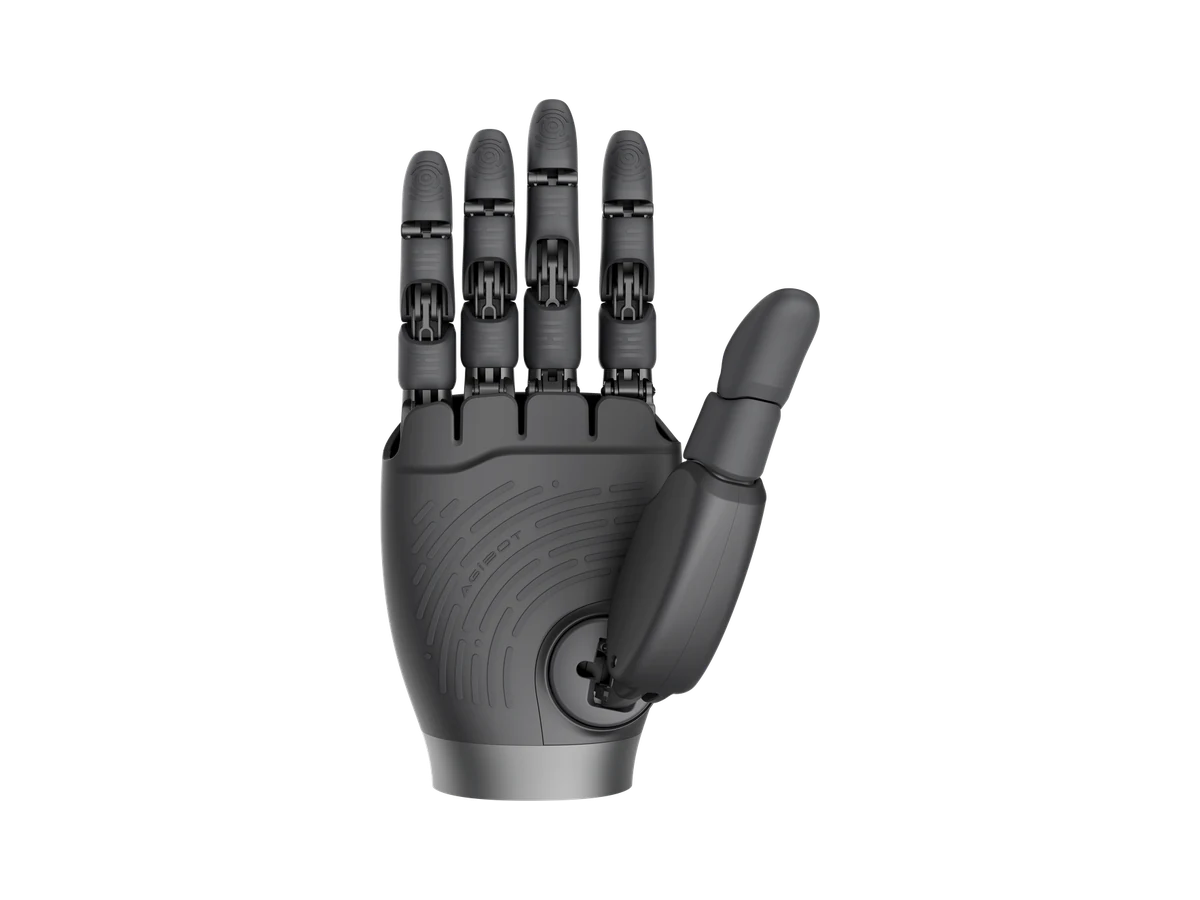
AGIBOT OmniHand
Compact dexterous hand with optional tactile sensing
Non-binding · no checkout
Manufacturer/supplier reference data, not independently verified. Configuration, EU conformity, safe integration and regional availability require confirmation before quotation.
At a glance
- Degrees of freedom
- 10 active + 6 passive
- Weight
- Configuration-specific value to be confirmed with quotation
- Dimensions
- 180 × 85 × 38.5 mm
OmniHand is a compact dexterous hand with 10 active and 6 passive degrees of freedom and CAN-FD / RS485 connectivity. Weight, tactile-sensor configuration and robot compatibility are confirmed for the selected variant.
- Pricing
- Individual quotation on request
- Availability
- Subject to project-specific confirmation
Highlights
- Compact design; compatibility depends on the robot model and selected variant
- Human-like gesture interaction including back-of-hand touch
- Optional tactile sensing; sensor count and safety requirements confirmed per configuration
- CAN-FD / RS485 interface
Specifications
Configuration note: Weight and tactile-sensor counts differ between reference documents and configurations. These values are withheld until the exact variant and options are confirmed.
| Degrees of freedom | 10 active + 6 passive |
|---|---|
| Weight | Configuration-specific value to be confirmed with quotation |
| Dimensions | 180 × 85 × 38.5 mm |
| Payload capacity | Five-finger gripping strength ≥ 5 kg |
| Arrayed sensors | Configuration-specific value to be confirmed with quotation |
| Force perception | Fingertips, palm and back of hand: 1D force |
| Array resolution | 0.1 N (with tactile option) |
| Interface | CAN-FD / RS485 |
Cited source: AGIBOT product brochure, April 2026 (OmniHand page); AGIBOT store listing.
Applications
- Reception & guided tours
- Research & development
- Data collection
More products in this category